
Announced September 22 at ROSCon in Toronto, Isaac ROS 5.0 introduces reusable AI-agent skills for robot setup, manipulation and perception. The skills are designed so coding agents can execute robotics-development workflows rather than only generate software code.
One new skill allows an AI agent to fine-tune NVIDIA’s FoundationStereo perception model for a developer’s specific cameras and operating environment. FoundationPose, NVIDIA’s foundation model for object pose estimation and tracking, now has an agent-ready inference library that NVIDIA says can identify and track the position and orientation of objects up to 5.5 times faster. Pick-and-place workflows combining detection, depth estimation and pose output are also available as standalone agent-ready skills. The performance figure is NVIDIA-reported.
Isaac ROS 5.0 moves to ROS 2 Lyrical and Ubuntu 24.04. NVIDIA also worked with the Open Source Robotics Alliance on a standard ROS data-handling interface that allows robotics applications to exchange data efficiently across different computing hardware, including GPUs. The release is available now as free, open-source software.
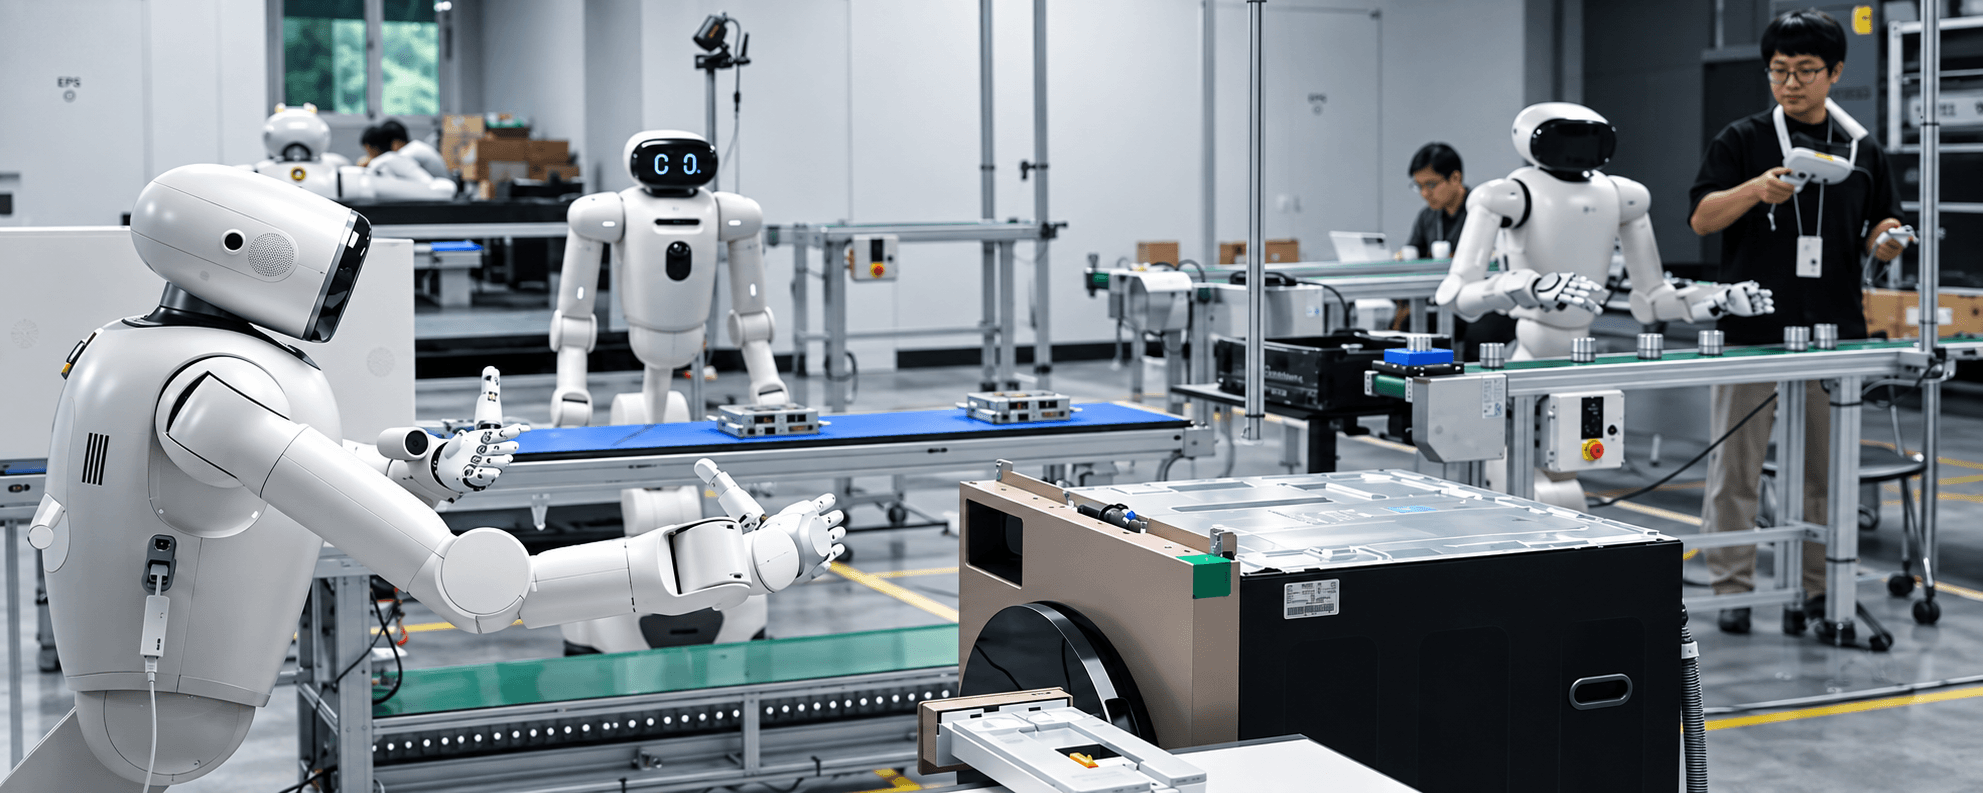
Several robotics companies are already integrating the stack. Mentee Robotics uses Isaac ROS as the perception and AI backbone of MenteeBot. FieldAI is integrating Isaac ROS with its robot foundation models for on-device inference, while Universal Robots has incorporated it into its AI Accelerator SDK. ROBOTIS is using it for vision-guided manipulation in its AI Worker robot.
Automotive supplier Magna is combining Isaac ROS with Isaac Sim hardware-in-the-loop testing and NVIDIA’s GR00T models for manufacturing and mobility applications. Intrinsic’s newly open-sourced machine-tending system also includes compatibility with FoundationPose.