Sensing
- Real-time terrain perception and fusion of self-perception plus environmental perception for complex terrain traversal


 LimX Dynamics
Humanoid research platform for perceptive walking, stair climbing and object handling.
LimX DynamicsHumanoid research platform for perceptive walking, stair climbing and object handling.
CL-1 is LimX Dynamics’ humanoid research platform for combining perception, locomotion and whole-body control. Manufacturer demonstrations show the robot adapting its steps to terrain, climbing stairs and negotiating curbs and slopes. In a simulated warehouse demonstration, CL-1 coordinated walking, squatting and lifting to move objects between a table and shelves at different levels. LimX reports handling packs weighing 4.1 kg and 8.2 kg in that test. These are demonstration object weights, rather than a published maximum payload rating or evidence of unrestricted industrial deployment.

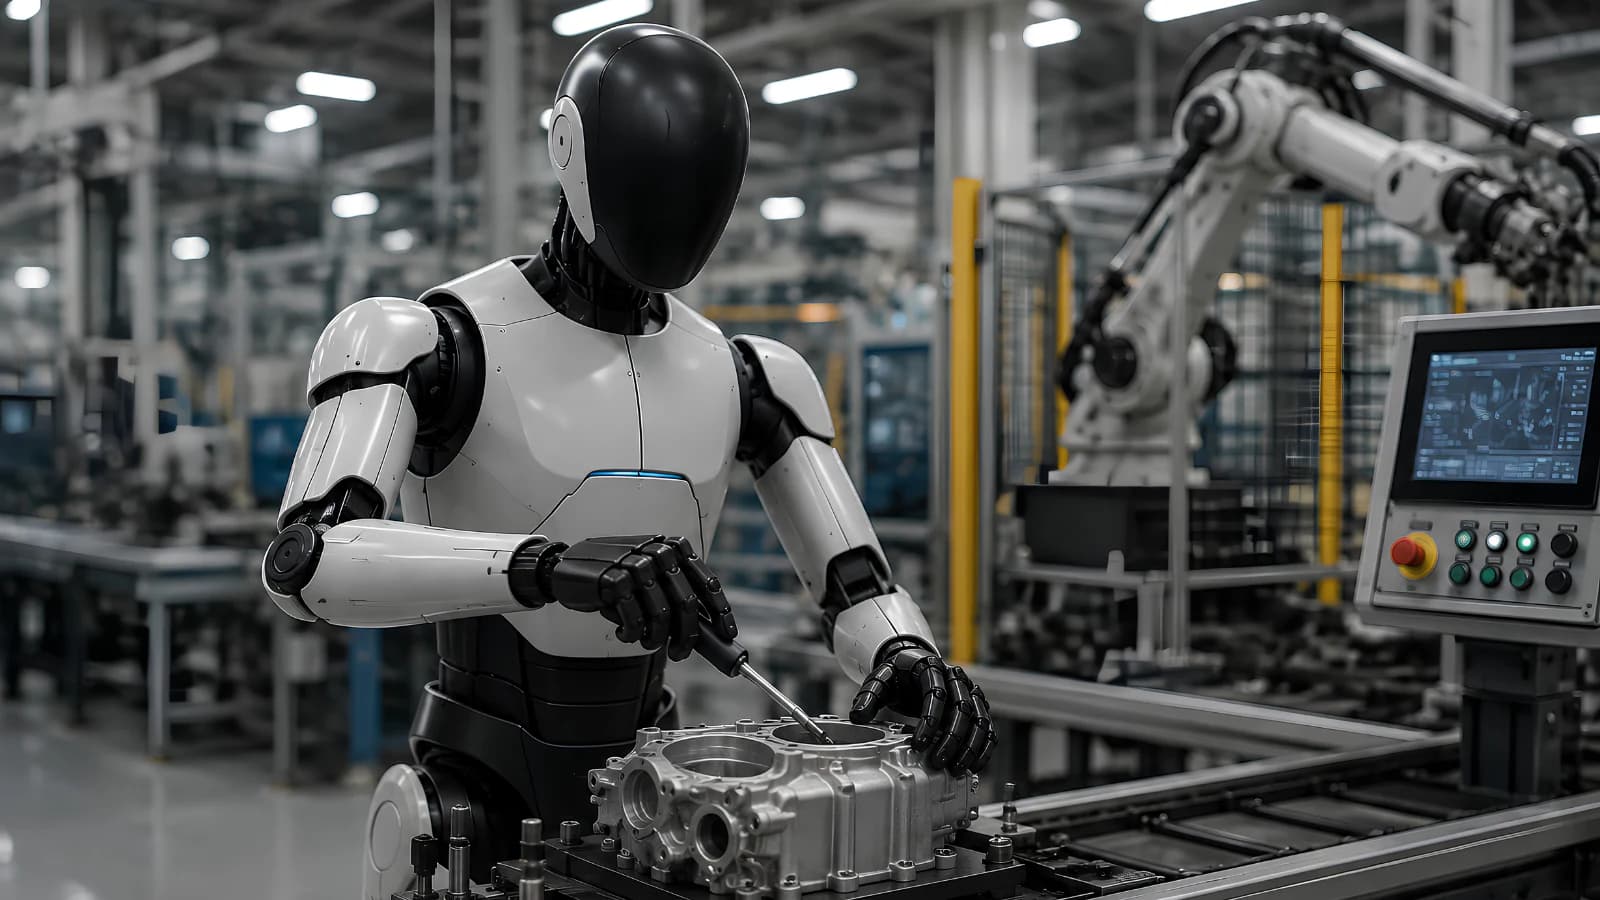
Manufacturing, assembly, inspection, and factory operations.
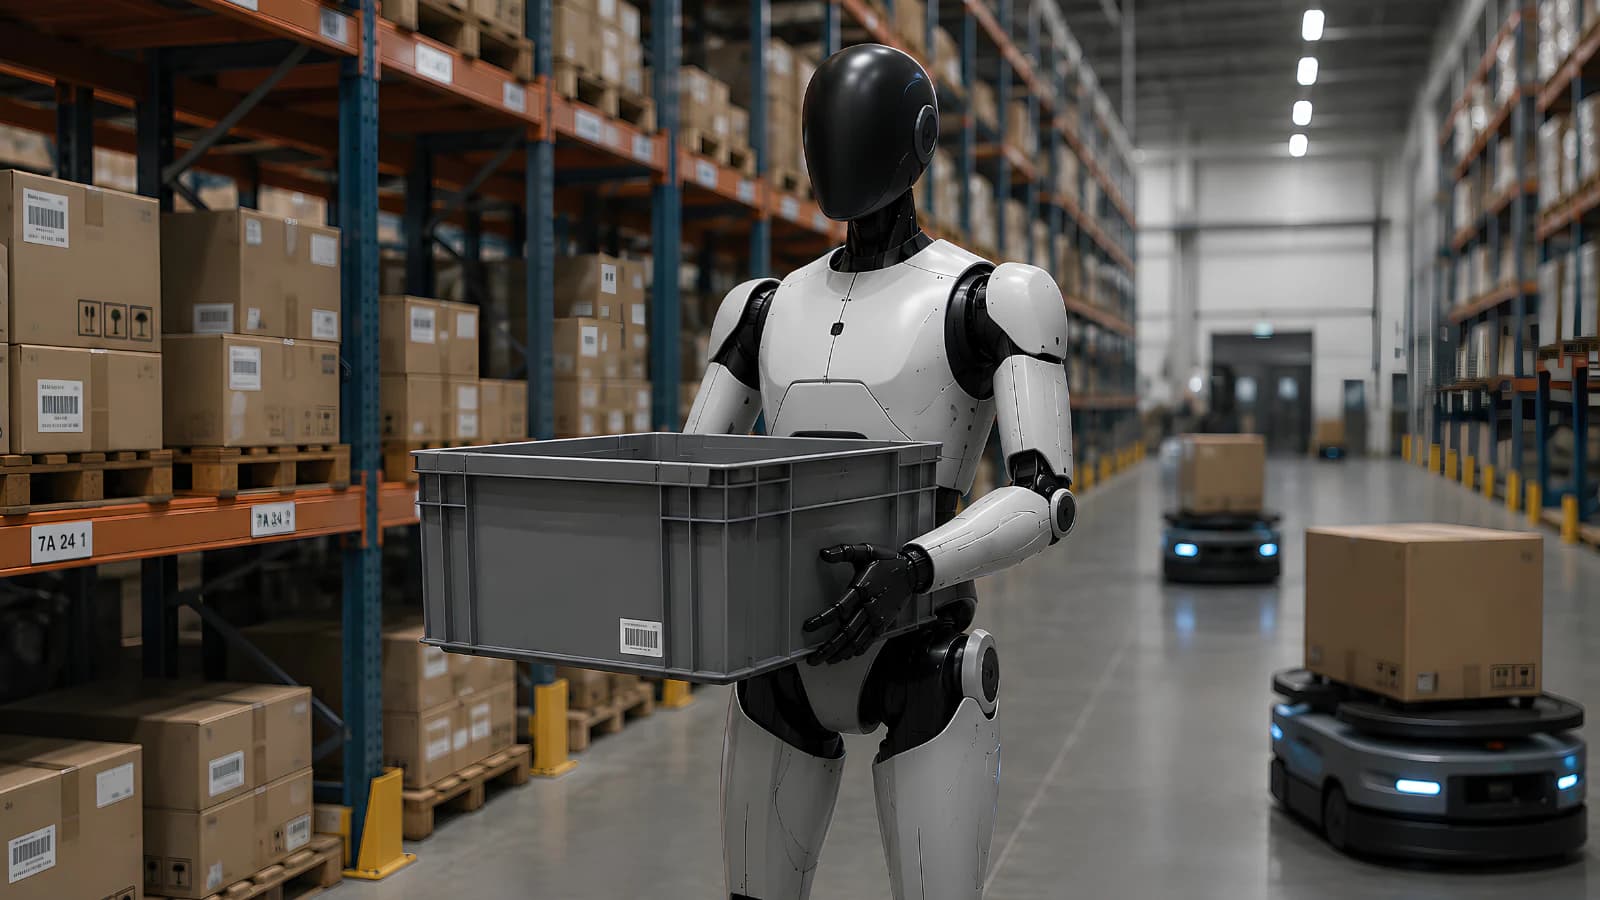
Picking, packing, sorting, inventory, and material handling.