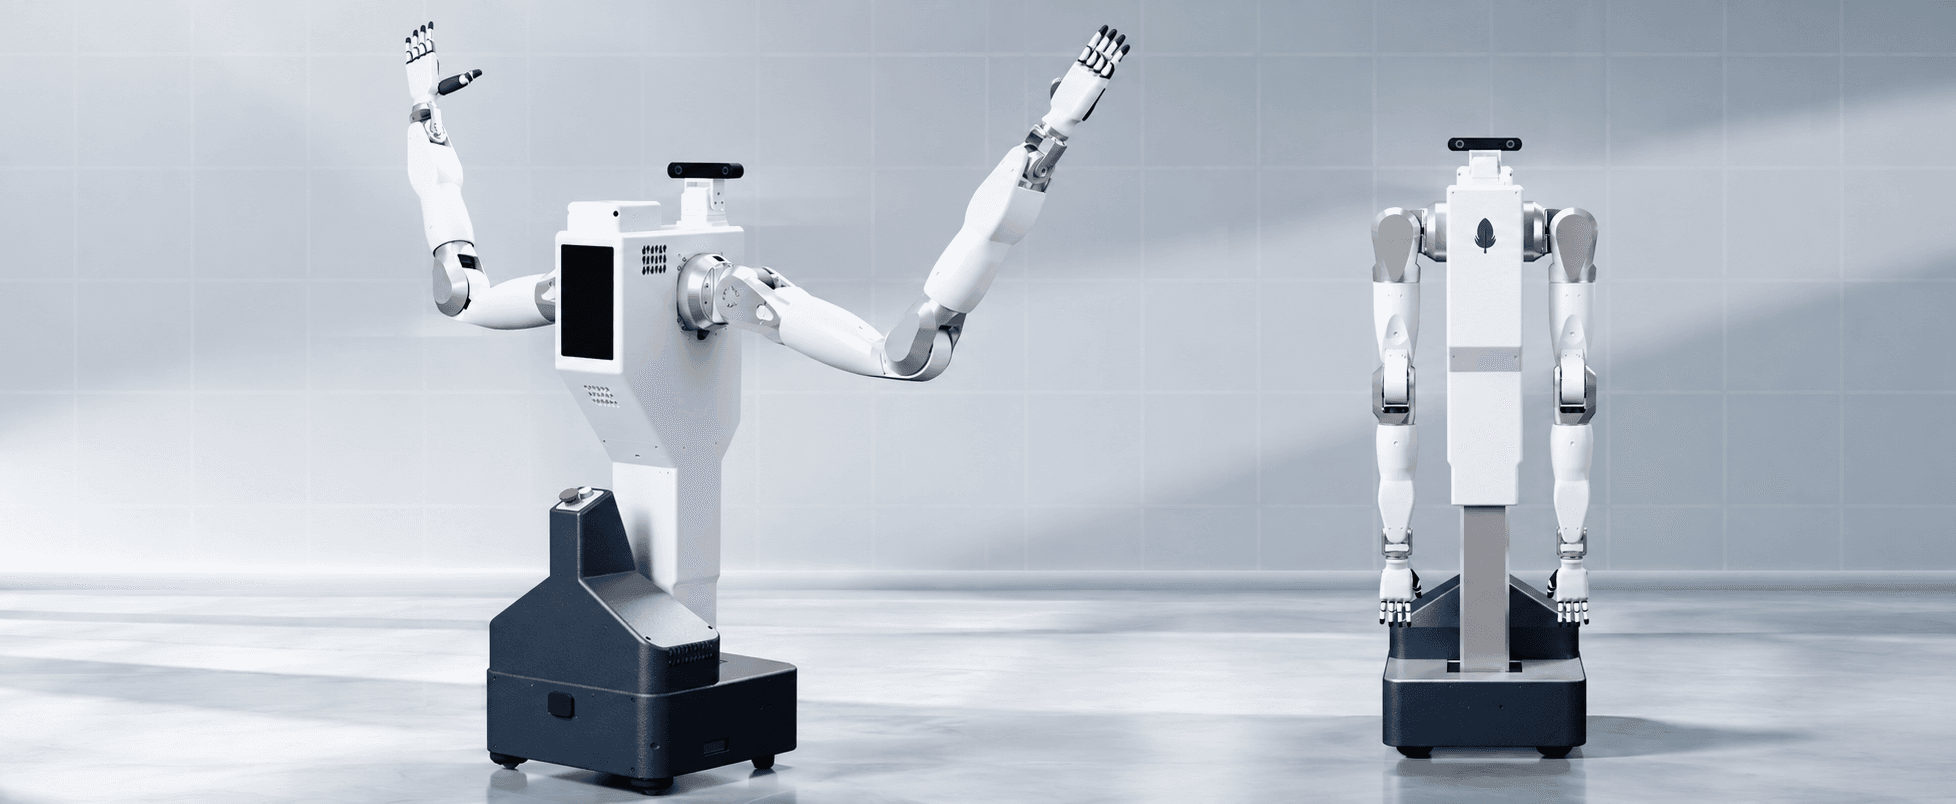
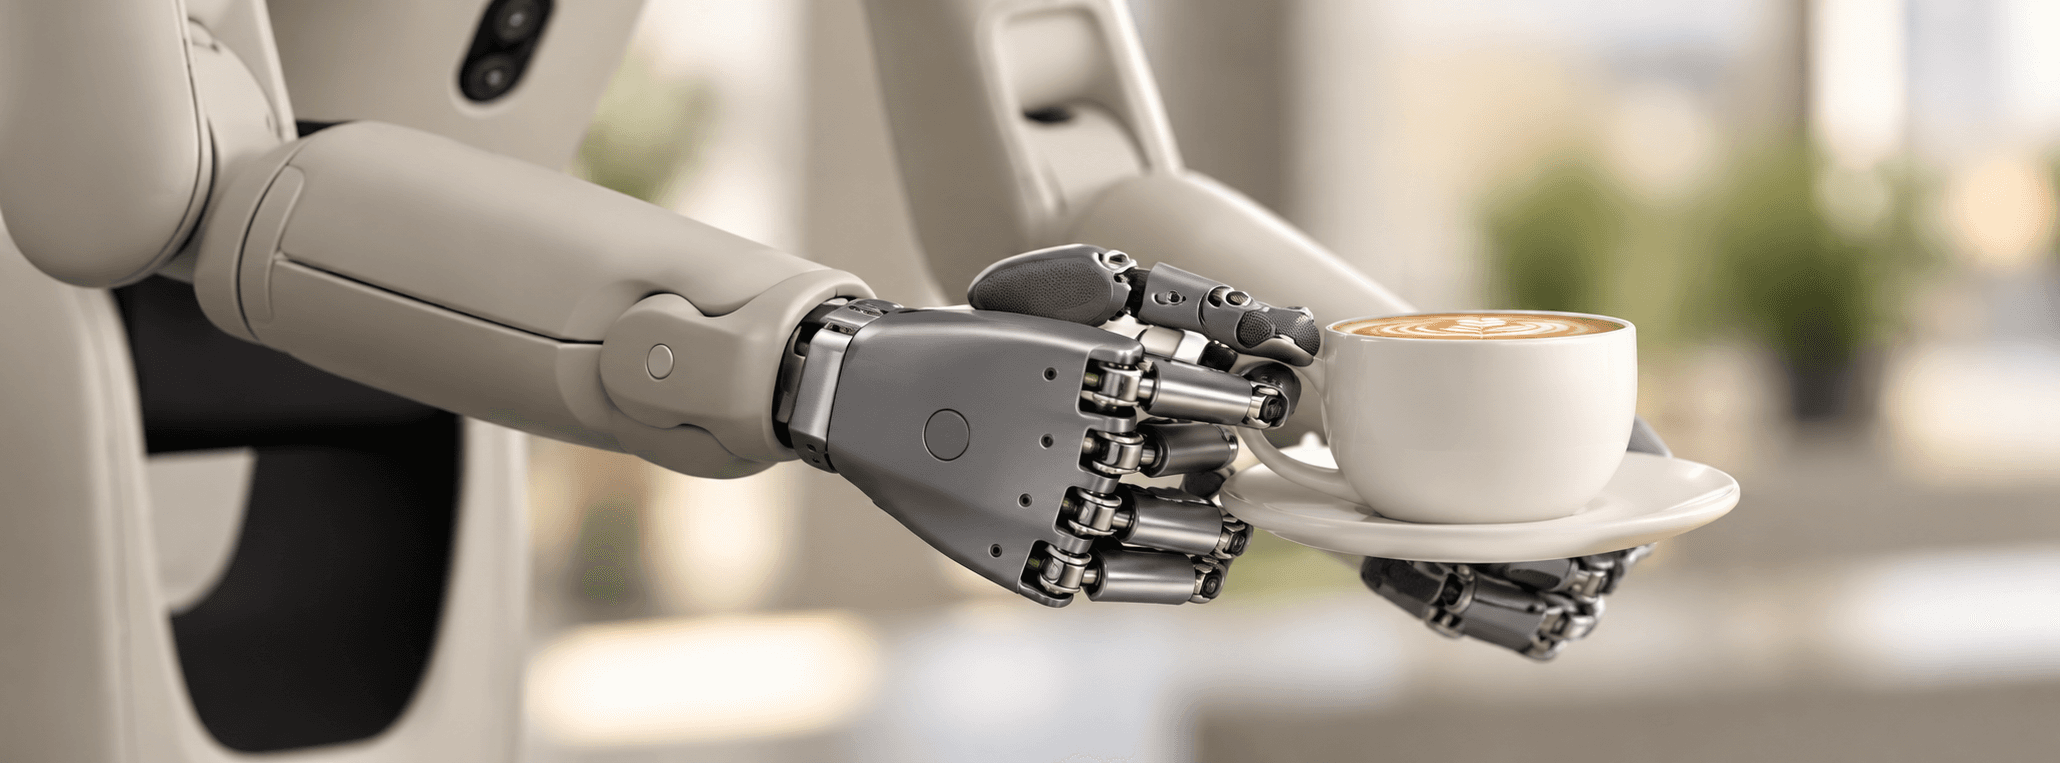

The D01 combines two seven-degree-of-freedom arms, Sharpa’s Wave hands, whole-body electronic skin and a native teleoperation system. Sharpa lists 66 total degrees of freedom, a weight of approximately 40 kilograms without its chassis and an Nvidia Jetson Thor processor.
Company specifications give each arm a rated payload of five kilograms, maximum end-effector speed above 10.5 metres per second and repeatability of ±0.2 millimetres. Its four-layer electronic skin has a stated force resolution of 0.2 newtons and samples tactile input at 100 Hz. Sharpa has opened the D01 for quote requests but has not disclosed pricing, delivery schedules or production targets.
The W02 is a human-scale hand weighing less than 750 grams, with 21 active degrees of freedom and tactile sensing across its fingertips, fingers and palm. Its fingertip sensors cover a force range of five millinewtons to 30 newtons at one-millimetre spatial resolution. The bare hand carries an IP54 rating, rising to IP67 with Sharpa’s official glove.
The AE01 captures motion through 22 encoders and returns haptic feedback through five fingertip vibration motors. Sharpa reports sub-one-millimetre fingertip-position repeatability, wired data output at 500 Hz and five-millisecond wired latency. The glove is designed for robot teleoperation and first-person demonstration-data collection.